About
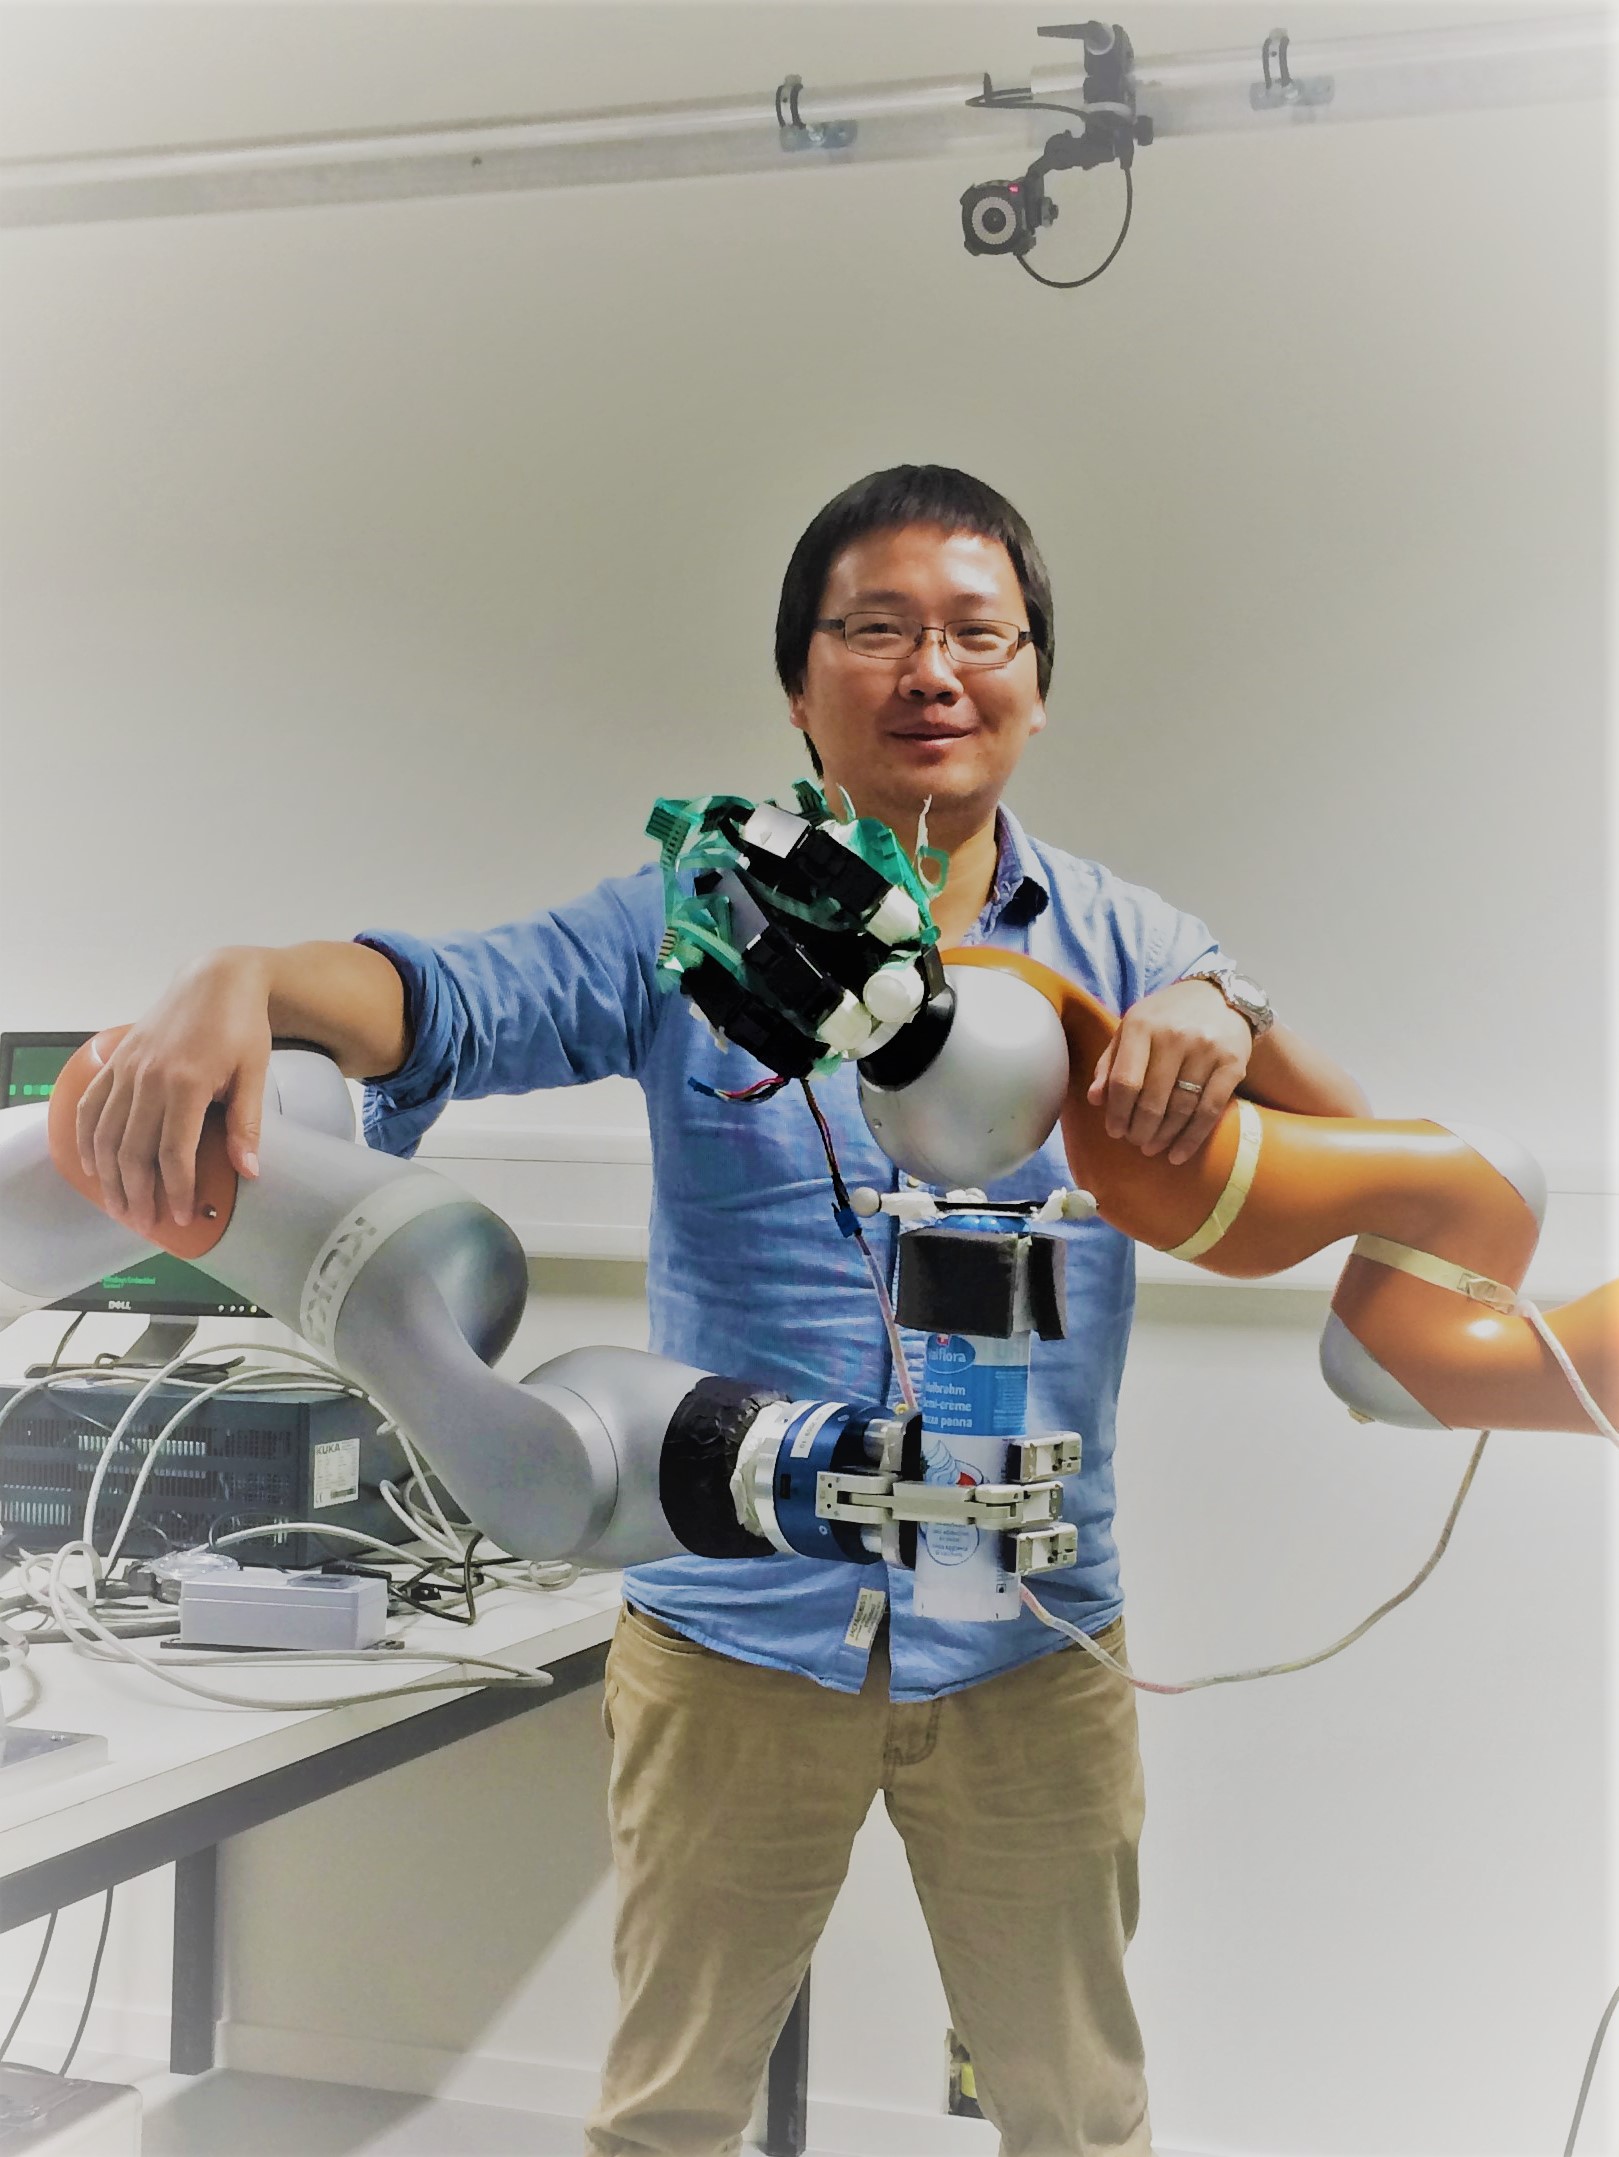
My research interests are in robotics, embodied robot learning, machine learning and applied nonlinear control. They encompass robot learning and control, object grasping and manipulation, human-robot interaction, robotic hands and tactile sensing, and neuroscience. Recent work follows three linked research themes: reliable grasping, dexterous manipulation, and collaborative robotic systems. I am particularly interested in finding the deep connections between dynamics of intelligent systems and learning algorithms (learning from humans or from optimizations), which enables adaptive, efficient and robust control design for complex systems. The goal of my research is to enable robots to perform skills with the level of dexterity and flexibility that human demonstrates in similar tasks. *I am also particularlly interested in finding the novel application of robotic grasping and manipulation in the real world.*
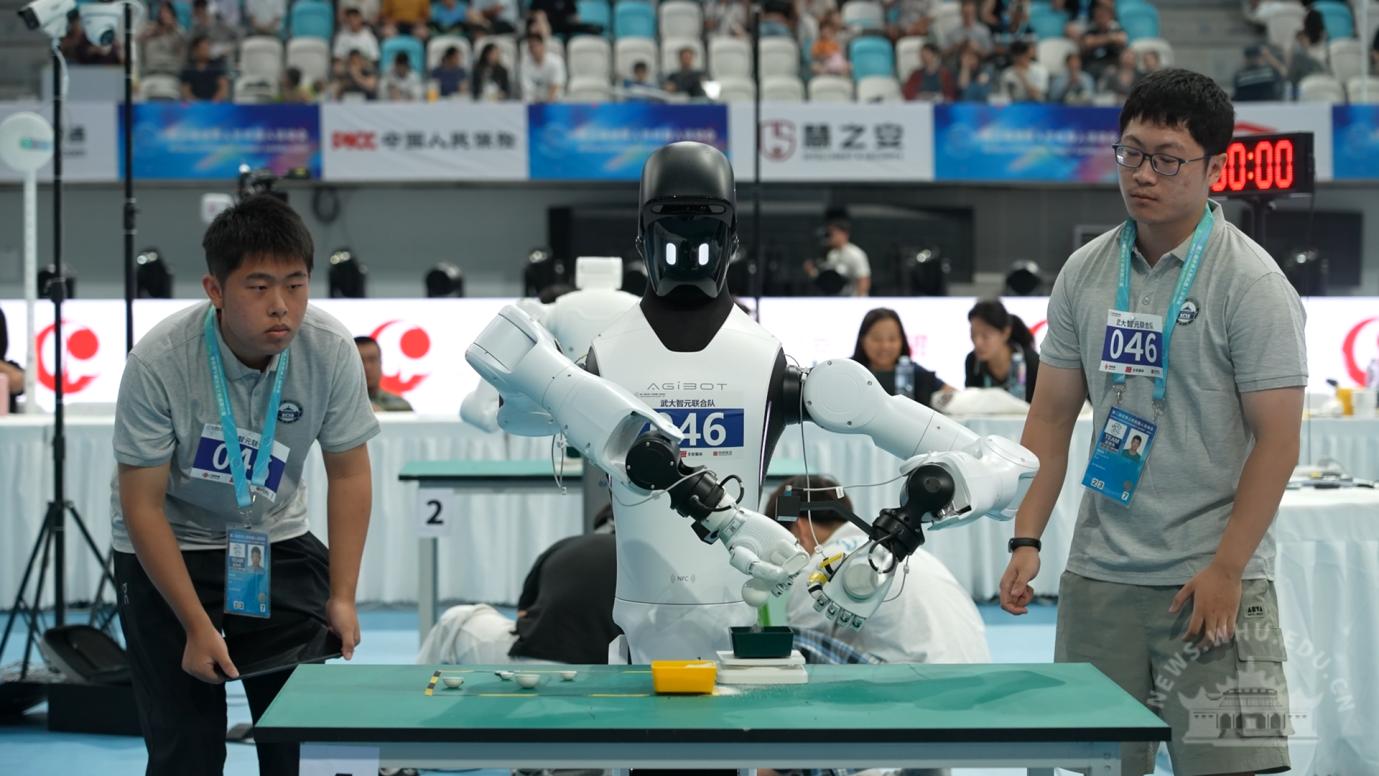
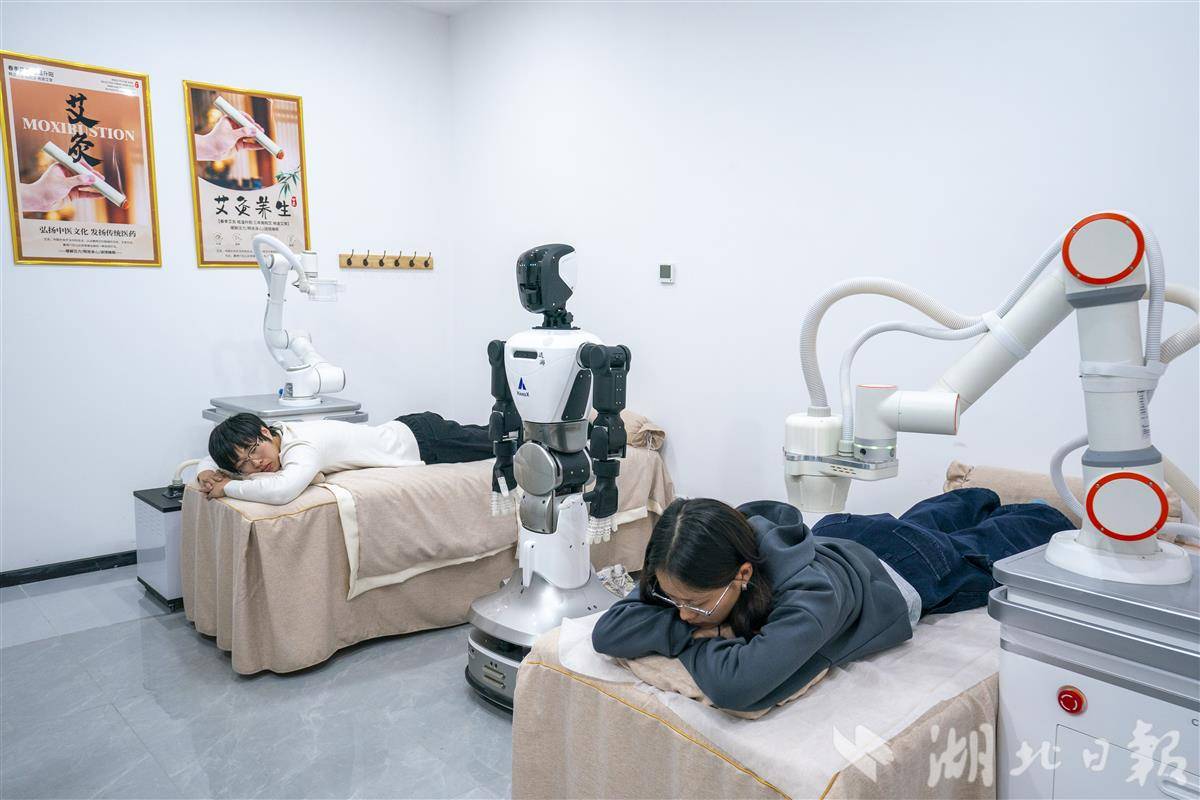
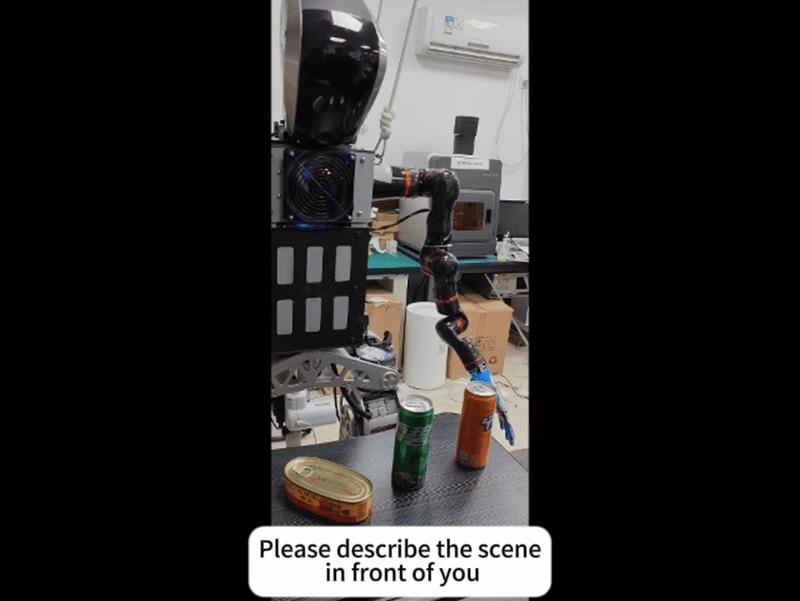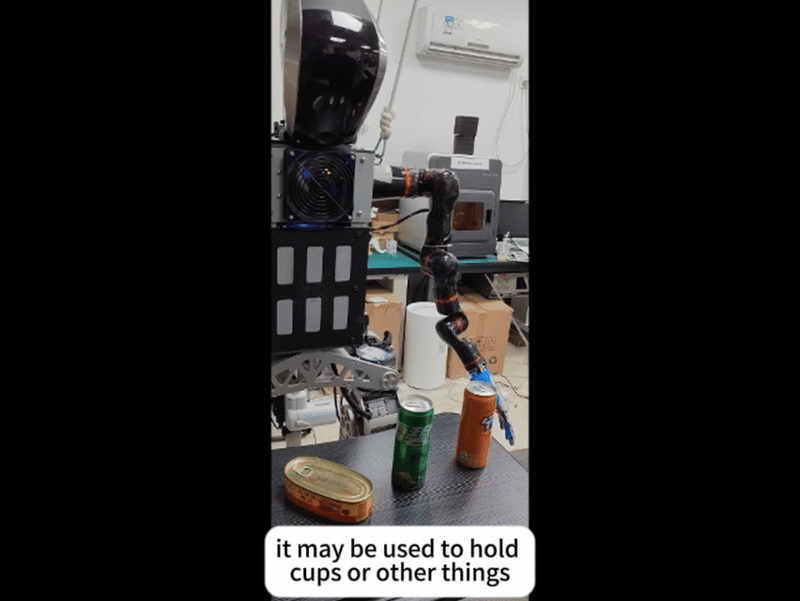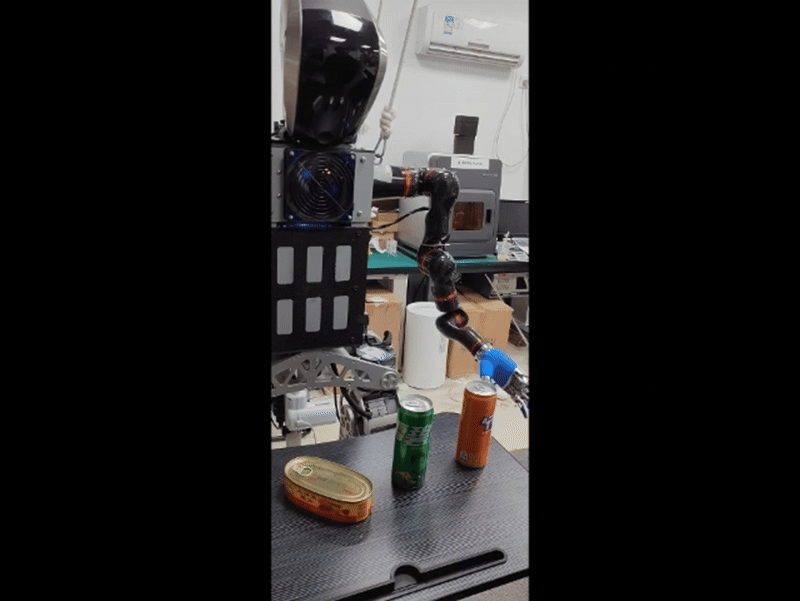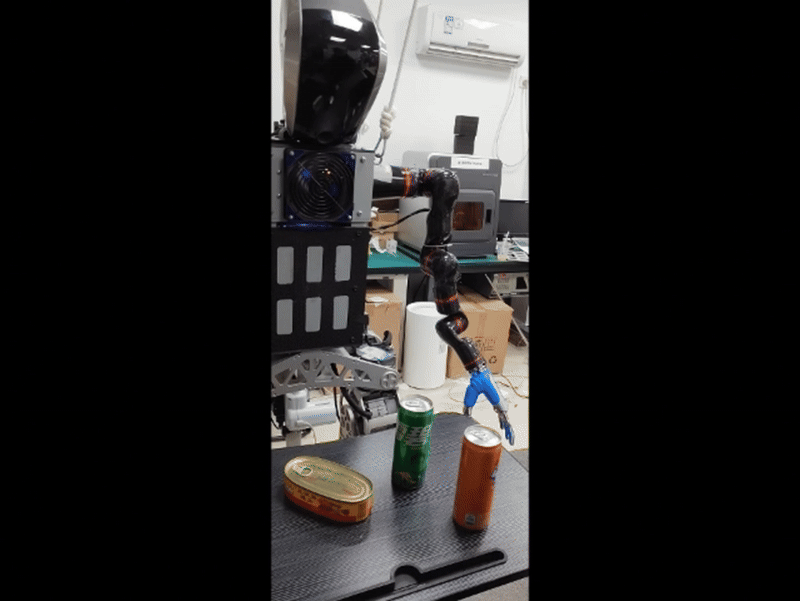
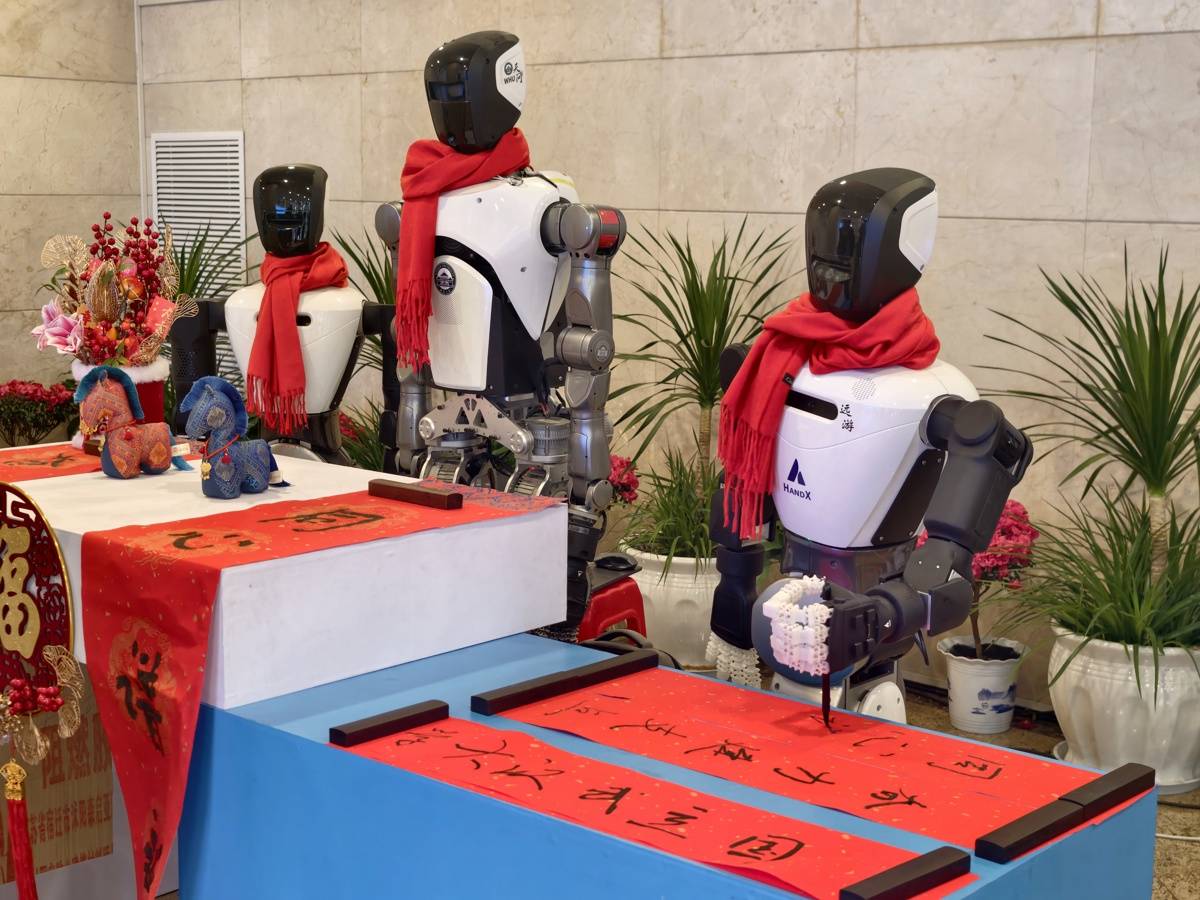
Research and Impact Highlights: My group's work centers on three questions: grasp reliably (grasp planning, tactile perception and adaptive control), manipulate with skill (contact-rich dexterous action, imitation learning and embodied AI), and work together (human–robot interaction and multi-robot collaboration). Our research has progressed from robotic hands and industrial picking to the Tianwen/Yuanyou humanoid platforms. Recent highlights include the 2026 World Humanoid Robot Games gold medal in autonomous dexterous powder weighing, AAAI 2026 RGMP on geometric-prior multimodal policy learning, and a contribution to the 2025 Red Dot award-winning dexterous hand. Beyond academia, I founded COBOT Technology (2016) and HandX Innovation (2024), connecting robotic research to industrial automation, tactile data collection and healthcare-related robotics. My work has also been recognized with the 2019 Hubei May 1st Labor Medal and the 2020 Innovation & Entrepreneurship Talents Award.
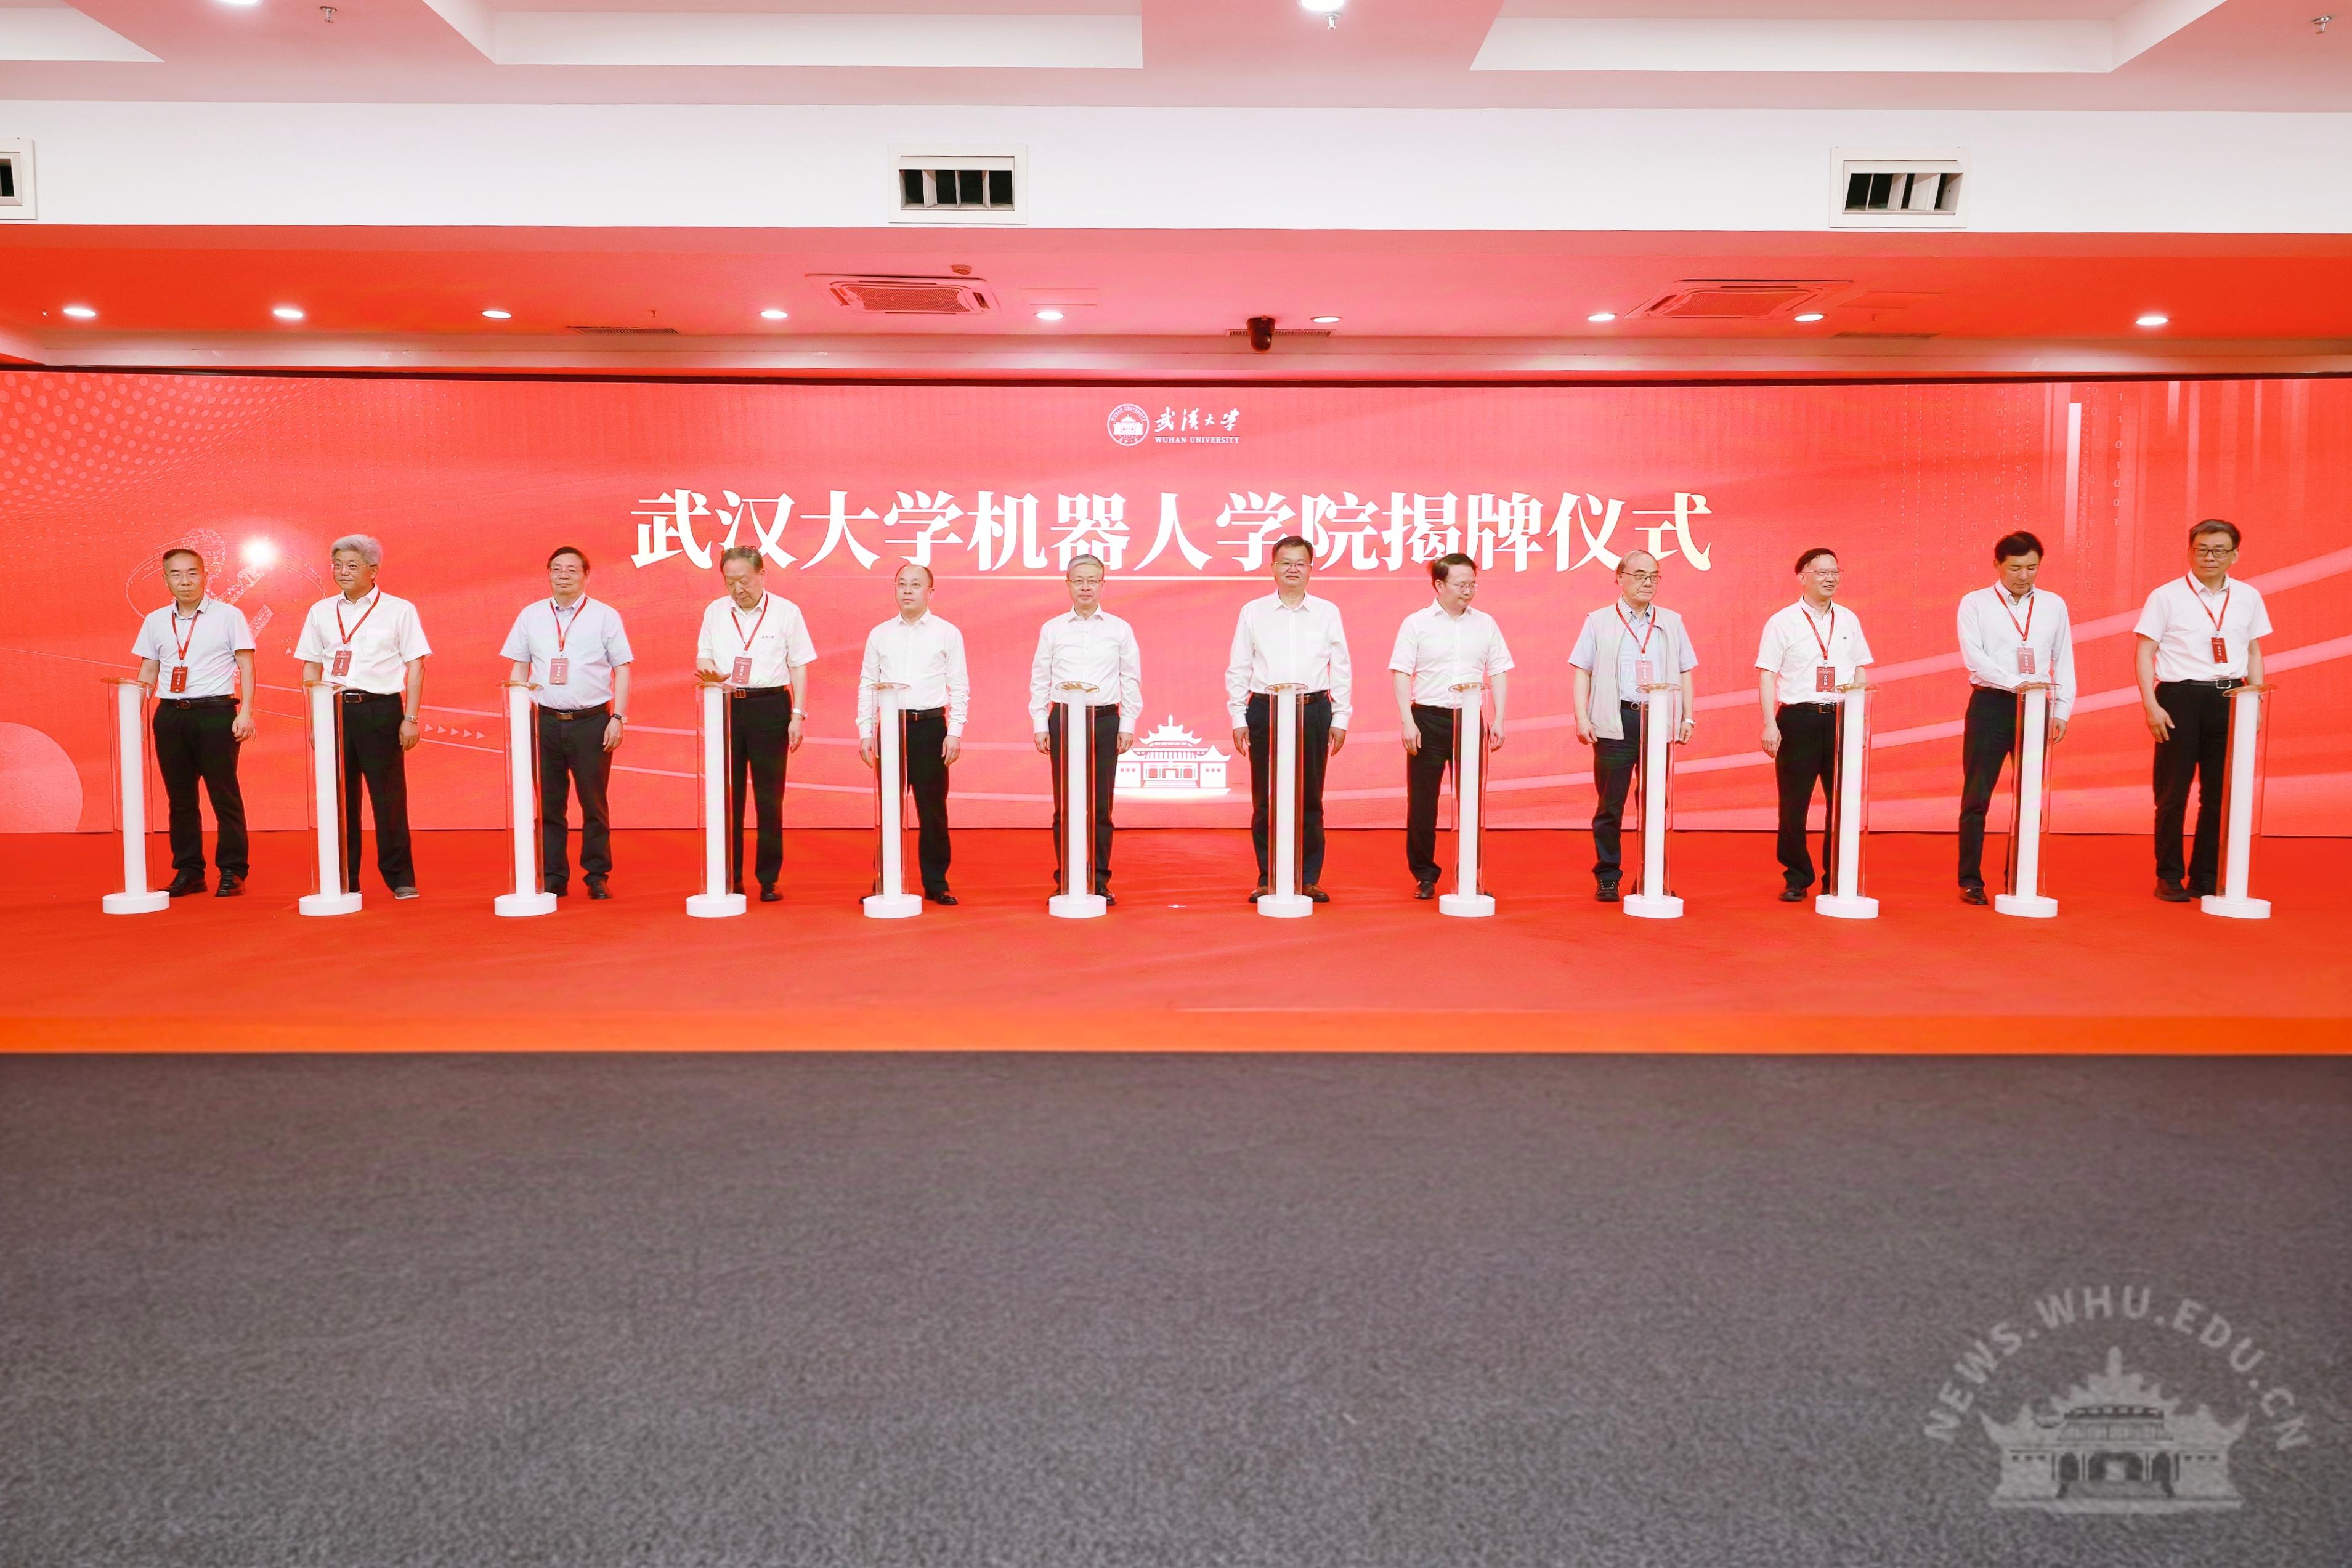
Short Bio: I am a professor in the School of Robotics at Wuhan University. I received my doctoral training at the Learning Algorithms and Systems Laboratory (LASA) at EPFL, Switzerland, working with Professor Aude Billard on dynamic grasp adaptation from humans to robots. Before that, I studied at Huazhong University of Science and Technology, China. I also co-founded COBOT Technology in 2016 and founded HandX Innovation in 2024, translating research on robotic manipulation into real-world systems.
My up-to-date (with some delay) can be found here: CV
If you are interested in our reseach, please drop me a line: limiao712@gmail.com
Teaching
I am teaching several courses for different schools including: Design and Manufacturing, Introduction to Robotics, Robotics.News
2024–2025 news


Older news archive (2016–2024)
2024-01
Two of our workshops have been accepted by ICRA 2024.
2023-10
I was invited to give a talk at IROS workshop of Robotics and AI for future factory (Robust Robotic Grasping-From Hundreds to Millions)
2023-09
I was invited to give a talk at 2023 Intel China Academic Excellence Program (Deep Imitation Learning for Robotic Grasping)
2023-09
We have submitted three papers and two workshop proposals to ICRA 2024
2023-09
I am severed as an AE for ICRA 2014
2023-09
This new semester I will teach a new course on robotics for HongYi Honor College
2022-09
We have submitted three papers to ICRA 2023
2022-09
Our paper "Robot Learning to Search Objects in Cluttered Environments Using Maximum Information-based Method" has been nominated as the Finalist of Best Paper Award in IEEE CYBER 2022.
2022-09
Our paper "A biomimetic tactile palm for robotic object manipulation" has been accepted by RAL.
2021-08
Our paper "Learning Robotic Ultrasound Scanning Skills via Human Demonstrations and Guided Explorations" has been nominated as the Finalist of T.J. Tarn Best Paper Award in ROBIO 2021.
2021-08
I am happy to be selected as the Academia Supervisor of HongYi Honor College of Wuhan University, China
2020-10
I am awarded with the Innovation and Entrepreneurship Talents Award, China.(10 persons per year in China)
2020-08
Our work on the robotic ultrasound system has won the second prize in Robot Innovation Design Competition for Chinese Graduate.
2019-05
I am awarded with the Hubei May 1st labor medal, Hubei Province.
2018-10
We just won the Best Paper Award in The 11th International Workshop on Human-Friendly Robotics.
2018-04
Our workshop submitted to IROS 2018 has been accepted from 84 proposals. Examining Sensing Modalities for Robust and Dexterous Object Manipulation, organized by Kaiyu Hang, Hao Ding, Miao Li, Danica Kragic and Aaron Dollar.
2018-02
Our paper on 'learning force-based skills from human demonstration' was submitted to IROS 2018.
2017-05
I will serve as a Guest Editor for Special Issue on Robotics & Automation Magazine, 2017 - Human-robot collaboration for production environments.
2017-02
Our workshop proposal Sensor-Based Object Manipulation for Collaborative Assembly at ICRA (Singapore, 2017) has been accepted!
2017-01
Visiting Researcher at Human-Centered Robotics Laboratory (Prof. Kenji Tahara), Kyushu University, Japan
2016-12
I started as an associate professor at Wuhan University, working on Learning Algorithms for Soft Manipulations.
2016-07
I started as a founder of a startup based in China-COBOT Technology, working on intelligent operation system for industrial robots.