Publications
Publications from 2020 to the present are arranged chronologically below, newest first. This list consolidates journal and conference publications from the lab website, DBLP and publisher records. For citation counts and the continuously updated record, please see Google Scholar.
Thumbnail policy: paper figures or graphical abstracts are used when a stable public source is available; otherwise a paper-specific visual card is shown rather than reusing an unrelated figure.
2026
- X. Deng, J. Zhao, Z. Yuan, B. Du, M. Li, and Z. Yang. Exploring magnetic actuation automation: Learning from noisy demonstrations via adaptive sampling policy. Engineering Applications of Artificial Intelligence, 163, 112902.
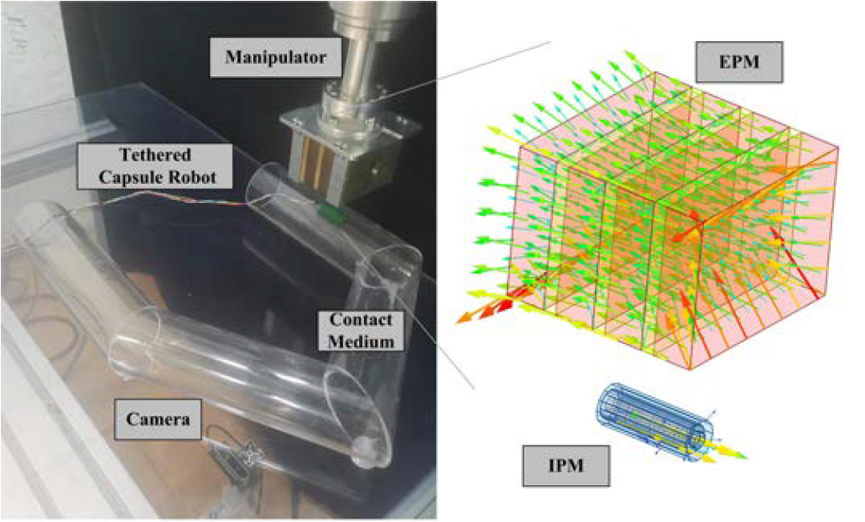
- X. Deng, H. Qi, J. Zhao, Z. Yuan, B. Du, M. Li, T. Zhang, and Z. Yang. Learning electromagnetic diffusion policies from mixed demonstrations in magnetic-assisted surgical contexts. Engineering Applications of Artificial Intelligence, 165, 113408.

- X. Deng, J. Zhao, Z. Yuan, M. Li, B. Du, and Z. Yang. Temporal Difference Policy for Dynamic Stability of Magnetically Actuated Objects With Uncertain Physical Properties. IEEE Transactions on Automation Science and Engineering, 23, 900–914.

- T. Teng, Y. Chen, C. Li, Z. Li, M. Li, C. Yang, D. G. Caldwell, and F. Chen. Passive Model Predictive Cooperative Interaction Control for Bimanual Humanoid Manipulation. IEEE Transactions on Automation Science and Engineering, 23, 5337–5349.
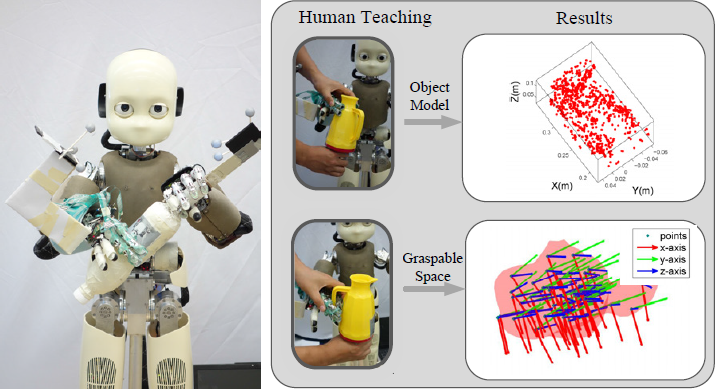
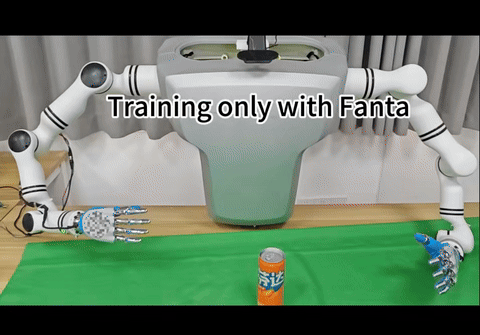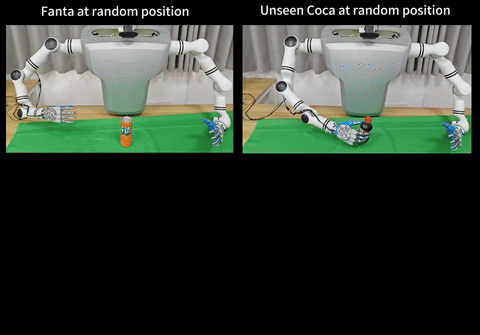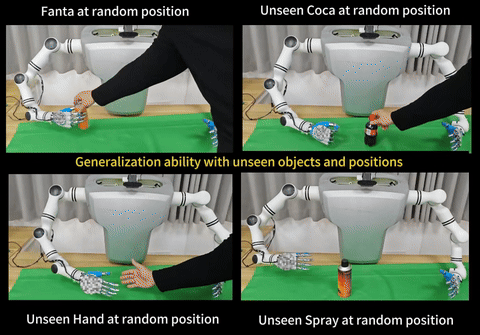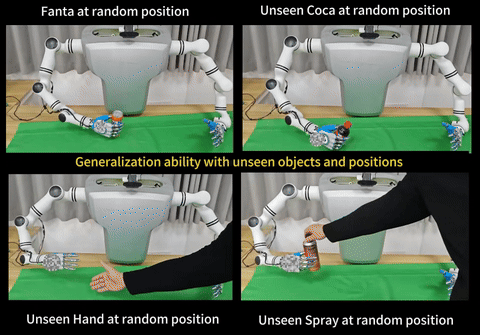
- X. Li, W. Huang, N. Pan, K. Zhao, S. Yang, Y. Wang, M. Li, M. Ye, J. Xuan, and M. Li. RGMP: Recurrent Geometric-prior Multimodal Policy for Generalizable Humanoid Robot Manipulation. AAAI 2026, 15153–15161.
- X. Li, P. Fu, W. Huang, N. Pan, S. Yang, K. Zhao, G. Wan, M. Li, J. Xuan, and M. Li. When Attention Betrays: Erasing Backdoor Attacks in Robotic Policies by Reconstructing Visual Tokens. ICRA 2026, 16876–16883.

- M. Li et al. Adaptive Dexterous Manipulation for Humanoid Robots via a Guided Tactile Multimodal Foundation Model. SCIENTIA SINICA Technologica.

- M. Li et al. A Motion-Aware and Grasp-Aware Cooperative System for Dexterous Soft Robotic Manipulation. SCIENTIA SINICA Technologica.

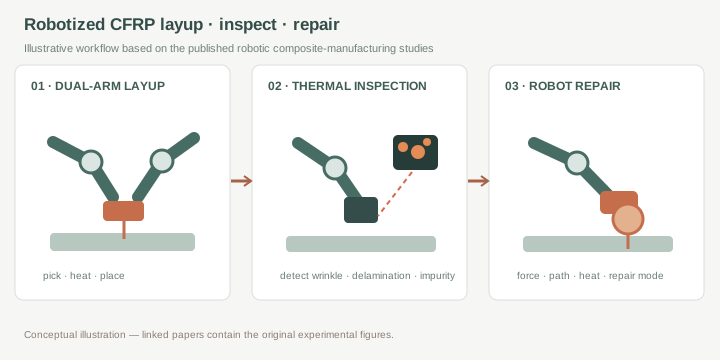
- X. Li, S. Liu, and M. Li. A defect-guided robotic in-process repair framework for carbon fibre composite layup defects. Nondestructive Testing and Evaluation.
- Y. He, S. Liu, and M. Li. From Simplified Markers to Muscle Function: A Deep Learning Approach for Personalized Cervical Biomechanics Assessment Powered by Massive Musculoskeletal Simulation. Sensors.
- S. Yang, Z. Liu, Y. Liu, X. Li, X. Fei, H. Huang, Z. Wang, and M. Li. Exploiting Vulnerabilities: Universal Adversarial Attacks on Vision-Language-Action Models in Robotics. arXiv preprint.

- S. Yang, Z. Liu, X. Li, R. Xiao, K. Zhu, and M. Li. ICI-VLA: In-Context Imitation with Spatiotemporally Aligned Demonstrations for Vision-Language-Action Models. arXiv preprint.

- X. Li, W. Huang, M. Ye, Z. Liu, J. Xie, J. Xuan, and M. Li. Generalizable Geometric Prior and Recurrent Spiking Feature Learning for Humanoid Robot Manipulation. arXiv preprint.

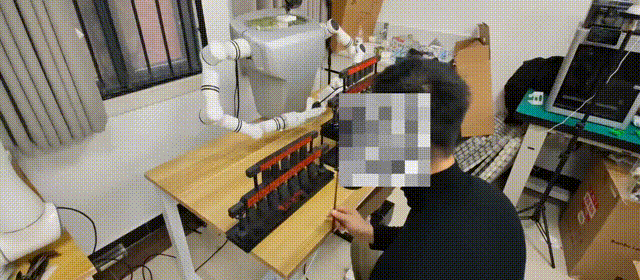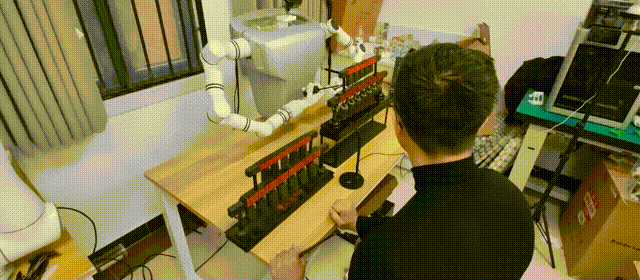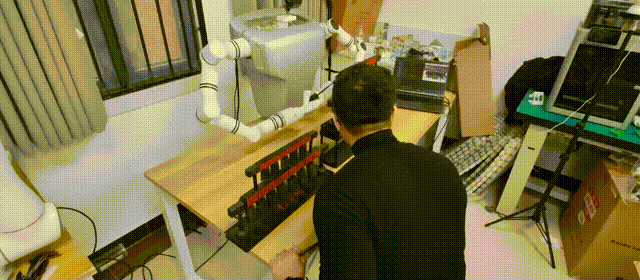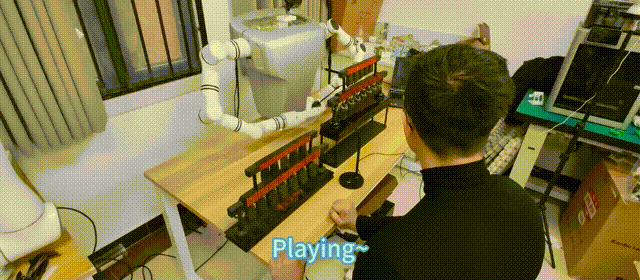
- X. Li, W. Huang, M. Ye, Z. Liu, J. Xie, J. Xuan, and M. Li. Co-policy: Responsive Human-Robot Co-Creation for Musical Performances. arXiv preprint.
2025
- X. Liu, K. Ma, Y. Sun, Y. Song, X. Zhang, A. Chen, X. Li, W. Huang, H. Shi, M. Li, Y. Zhou, and S. Liu. Analytical and Optimal Strategy of Dynamic Current Balancing for Paralleled SiC MOSFETs With Cu-Clip Interconnection Considering Mutual Coupled Inductances. IEEE Transactions on Components, Packaging and Manufacturing Technology.
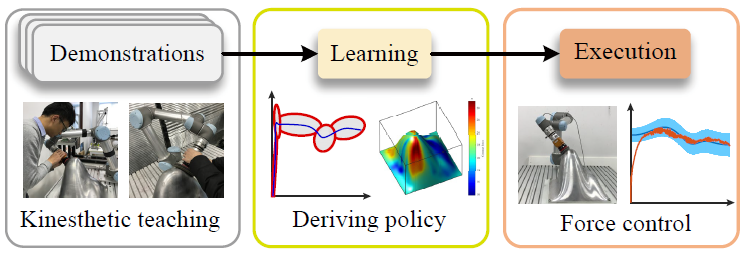
- X. Li, R. Zhou, Y. Gong, et al., and M. Li. Learning Flexible-Rigid Surface Contact Skills from Human Demonstrations. Preprint, 2025.
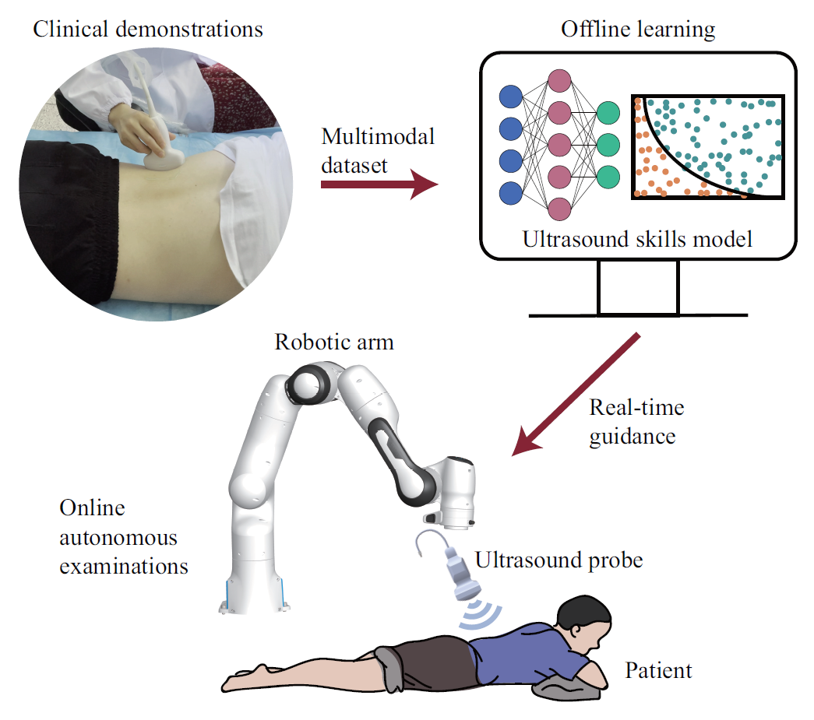
- X. Deng, J. Jiang, W. Cheng, C. Yang, and M. Li. Learning Freehand Ultrasound Through Multimodal Representation and Skill Adaptation. IEEE Transactions on Automation Science and Engineering, 22, 5117–5130.

- Y. Chen, A. E. Tekden, M. Li, D. Kanoulas, and Y. Bekiroglu. Learning Pixel-Wise Suction Grasp Representation for Cluttered Environments. IEEE CASE 2025, 3488–3493.

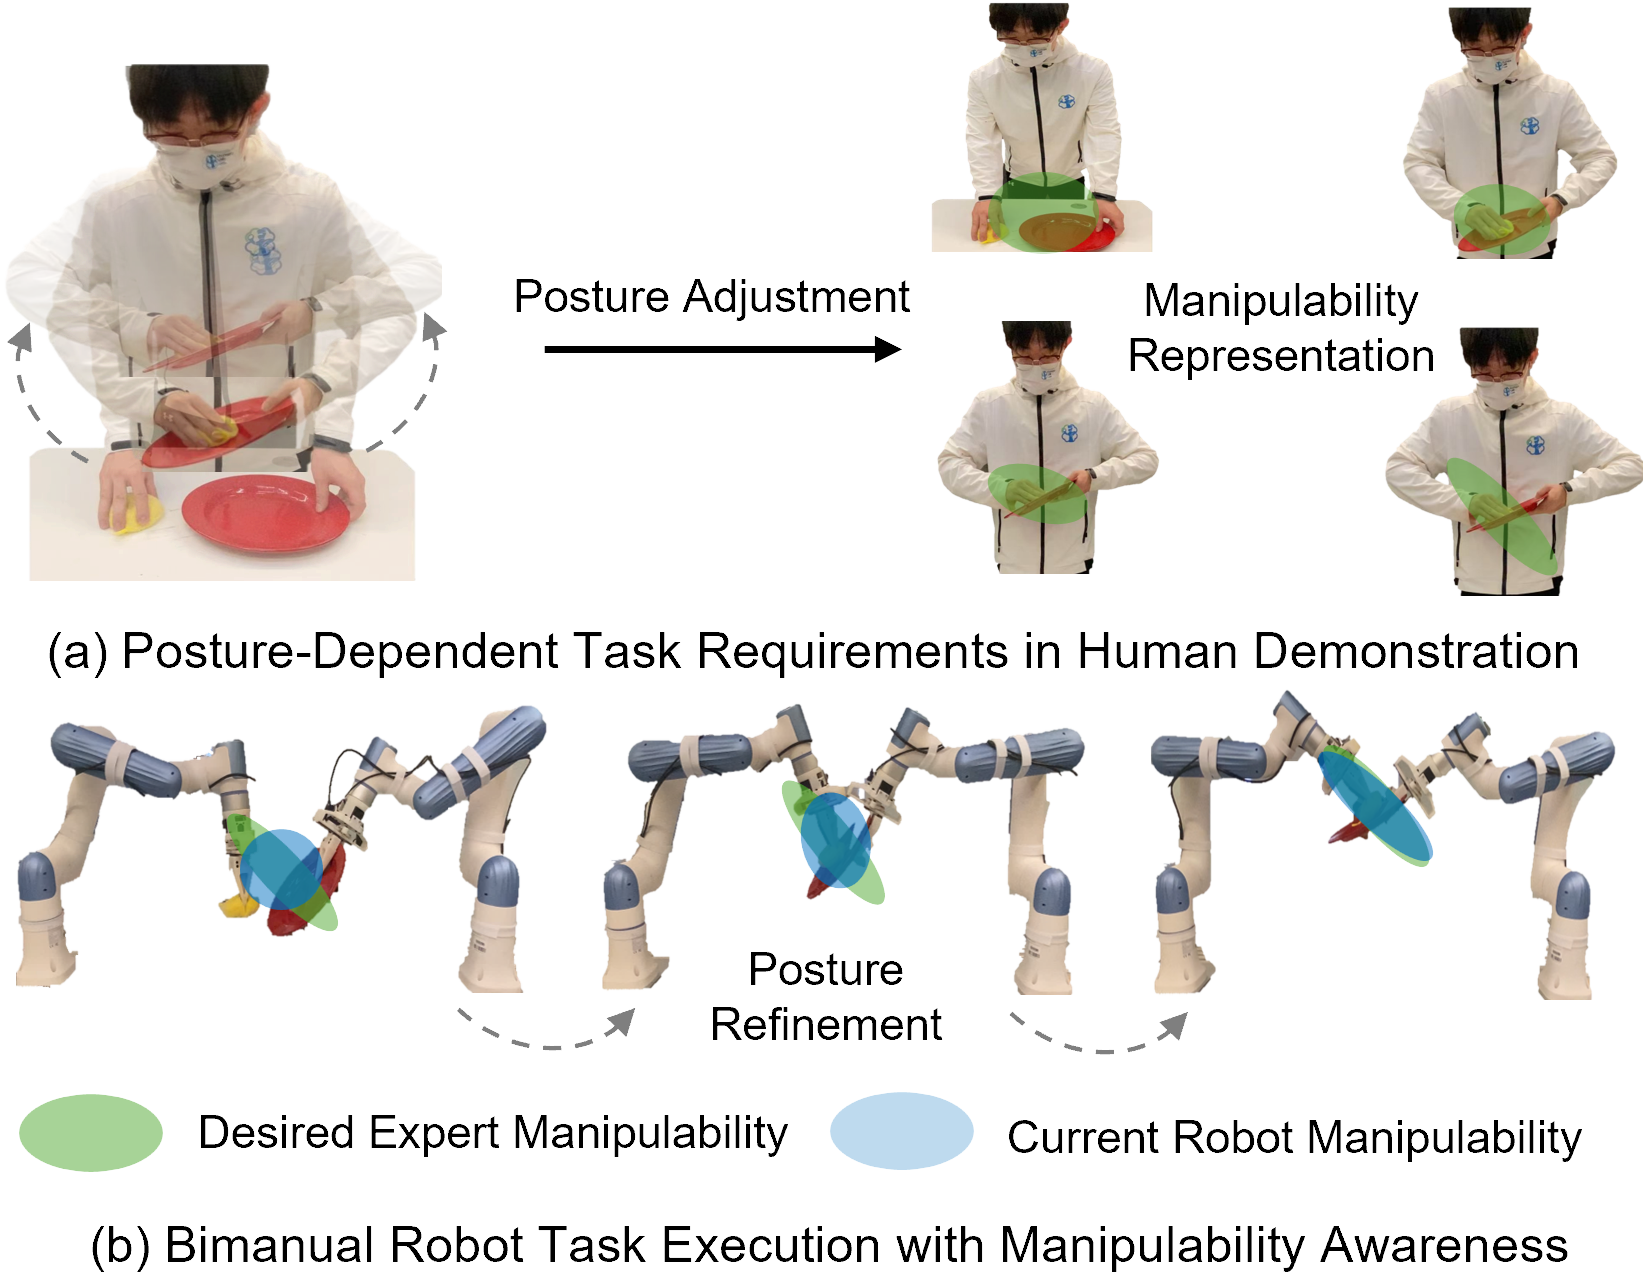
- Z. Li, J. Liu, D. Li, T. Teng, M. Li, S. Calinon, D. G. Caldwell, and F. Chen. ManiDP: Manipulability-Aware Diffusion Policy for Posture-Dependent Bimanual Manipulation. IROS 2025, 9956–9962.
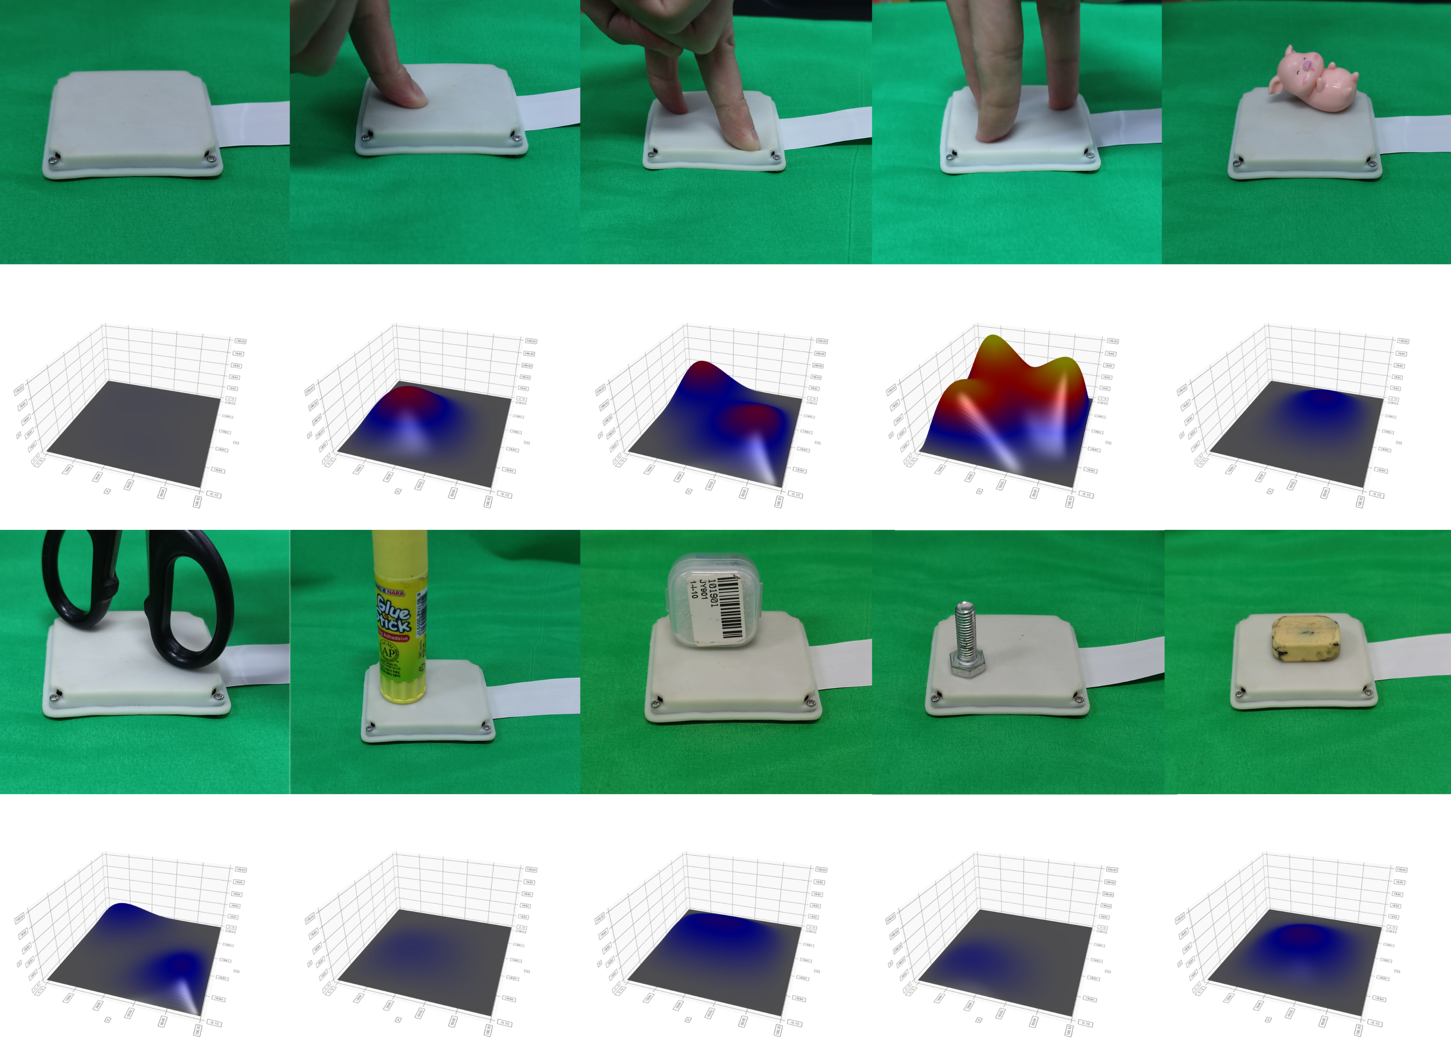
- M. Li, F. Zhao, X. Li, M. Li, S. Liu, and M. Li. Design and Fabrication of a Piezoresistive Tactile Sensor Inspired by Human Skin Microstructure for Robotic Manipulation. IEEE Sensors Journal, 25(6), 10466–10475.
- Y. Gong, X. Li, R. Zhou, M. Li, and S. Liu. A robotized framework for real-time detection and in-situ repair of manufacturing defects in CFRP patch placement. Robotics and Computer-Integrated Manufacturing, 92, 102882.

- Y. Gong, R. Zhou, X. Li, S. Wang, M. Li, and S. Liu. Multi-task learning for predicting residual mechanical properties of CFRP laminates after impact. Composites Science and Technology, 261, 111054.

- Y. Gong, X. Li, R. Zhou, M. Li, and S. Liu. Deep reinforcement learning-based patch bonding method for damage repair of laminates. Composites Part A: Applied Science and Manufacturing, 109403 (online 2025).

2024
- H. Su, J. Weng, Z. Liu, M. Li, Y. Liu, Y. Zhong, and W. Sun. MTDCAP: Moving Target Defense-Based CAN Authentication Protocol. IEEE Transactions on Intelligent Transportation Systems, 25(9), 12800–12817.
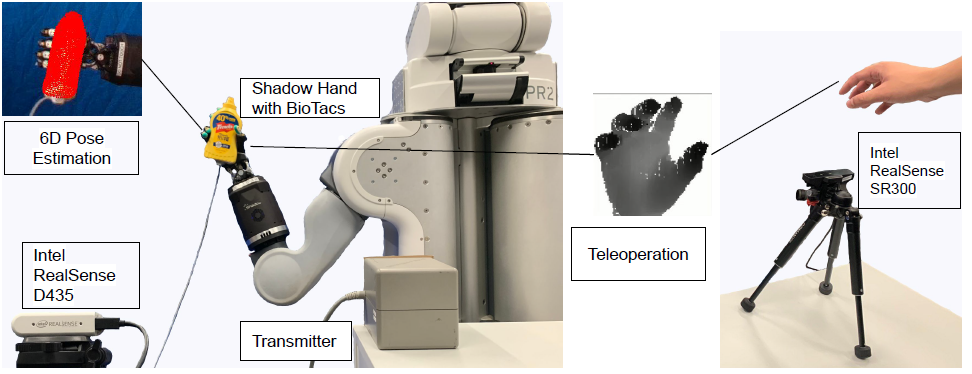
- X. Li, R. Zhou, W. Wang, M. Li, Y. Gong, and M. Li. Path planning for dual-arm fiber patch placement with temperature loss constraints. Engineering Applications of Artificial Intelligence, 133, 108518.

- M. Li, X. Deng, F. Zhao, M. Li, S. Liu, and M. Li. Learning automatic navigation control skills for miniature helical robots from human demonstrations. Engineering Applications of Artificial Intelligence, 137, 109187.

- M. Li, J. Pang, and F. Cen. Challenges in Developing Robotic Systems Based on Large Language Models. International Journal of Artificial Intelligence and Robotics Research, 1(3&4), 2501001.
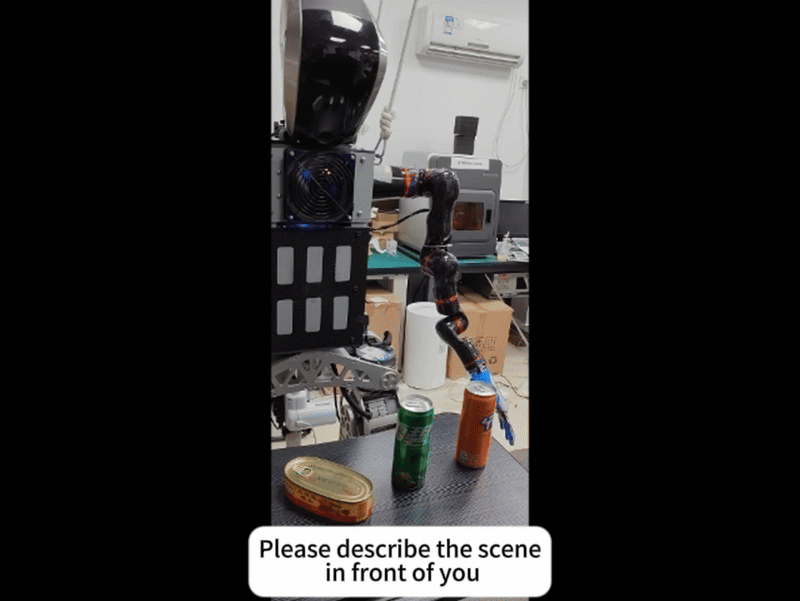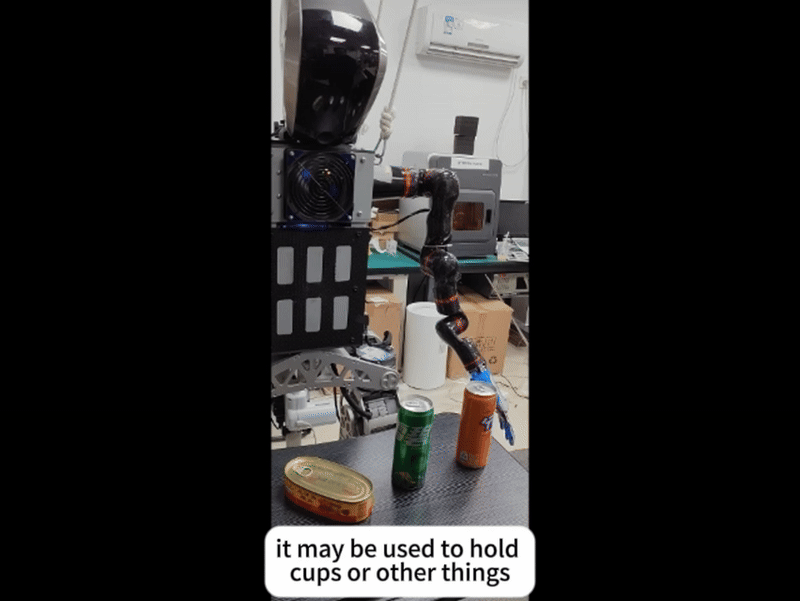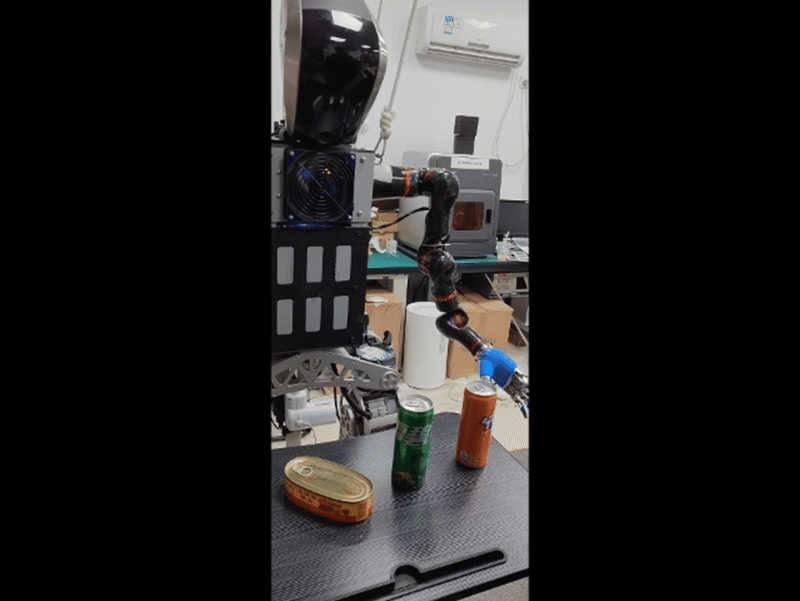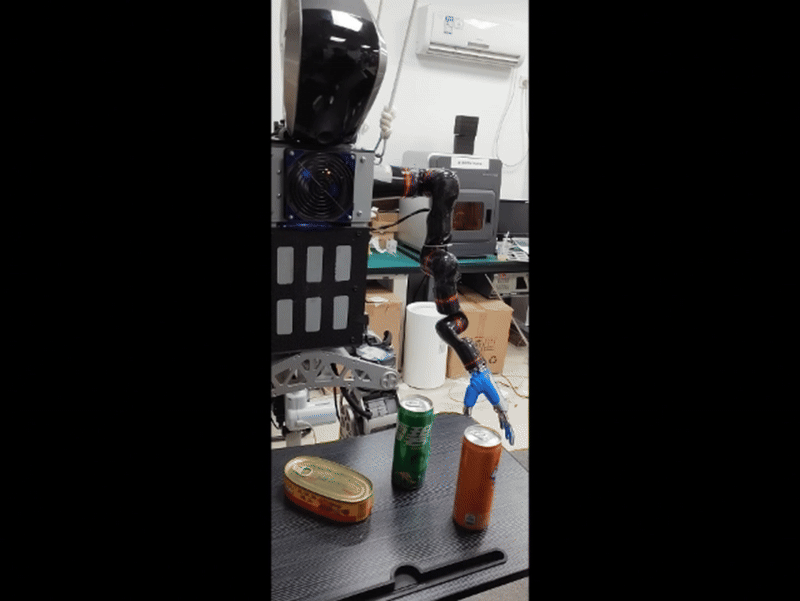
- X. Deng, J. Zhao, Z. Yuan, M. Li, B. Du, and Z. Yang. Freehand Interaction With Visual Control and Haptic Feedback in Electromagnetically Assisted Interventional Surgery. IEEE Internet of Things Journal, 11(24), 40845–40860.
%22%20fill%3D%22none%22%20stroke%3D%22%23c96482%22%20stroke-width%3D%223%22%20stroke-linecap%3D%22round%22%3E%0A%20%20%20%20%3Ccircle%20cx%3D%2222%22%20cy%3D%2222%22%20r%3D%2218%22%2F%3E%3Cpath%20d%3D%22M6%2022h32M22%206v32%22%2F%3E%3Cpath%20d%3D%22M10%2012l24%2020M34%2012L10%2032%22%2F%3E%0A%20%20%3C%2Fg%3E%0A%3C%2Fsvg%3E)
- X. Lei, Z. Fu, E. Spyrakos-Papastavridis, J. Pan, M. Li, and X. Chen. IHUVS: Infinite Homography-Based Uncalibrated Methodology for Robotic Visual Servoing. IEEE Transactions on Industrial Electronics, 71(4), 3822–3831.

- Y. Zhuang, Q. Li, Y. Chen, J. Huai, M. Li, T. Ma, Y. Tang, and X. Liang. 3D-SeqMOS: A Novel Sequential 3D Moving Object Segmentation in Autonomous Driving. IEEE Transactions on Intelligent Transportation Systems, 25(8), 8782–8795.

- M. Li, F. Zhao, X. Li, M. Li, S. Liu, and M. Li. Design and Fabrication of a Novel Miniature Magnetic Gripper. ICRA 2024, 1964–1970.
- R. Zhang, W. Zhou, M. Li, and M. Li. Design of a Double-joint Robotic Fish Using a Composite Linkage. CIS-RAM 2024, 279–283.
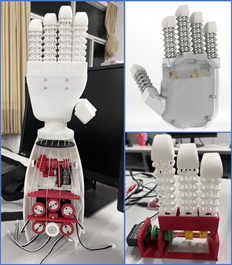
- Z. Li, J. Liu, Z. Li, M. Yu, T. Teng, S. Zhou, M. Li, T. L. Lam, and F. Chen. Instruction-Following Long-Horizon Manipulation by LLM-Empowered Symbolic Planner. ROBIO 2024, 913–918.

- J. Liu, C. Li, S. Wang, Z. Dong, T. L. Lam, S. Calinon, M. Li, and F. Chen. Learning Goal-oriented Bimanual Dough Rolling Using Dynamic Heterogeneous Graph Based on Human Demonstration. ROBIO 2024, 925–930.

- Y. Hu, M. Li, S. Yang, X. Li, S. Liu, and M. Li. Learning Robust Grasping Strategy Through Tactile Sensing and Adaption Skill. ROBIO 2024, 1197–1202.
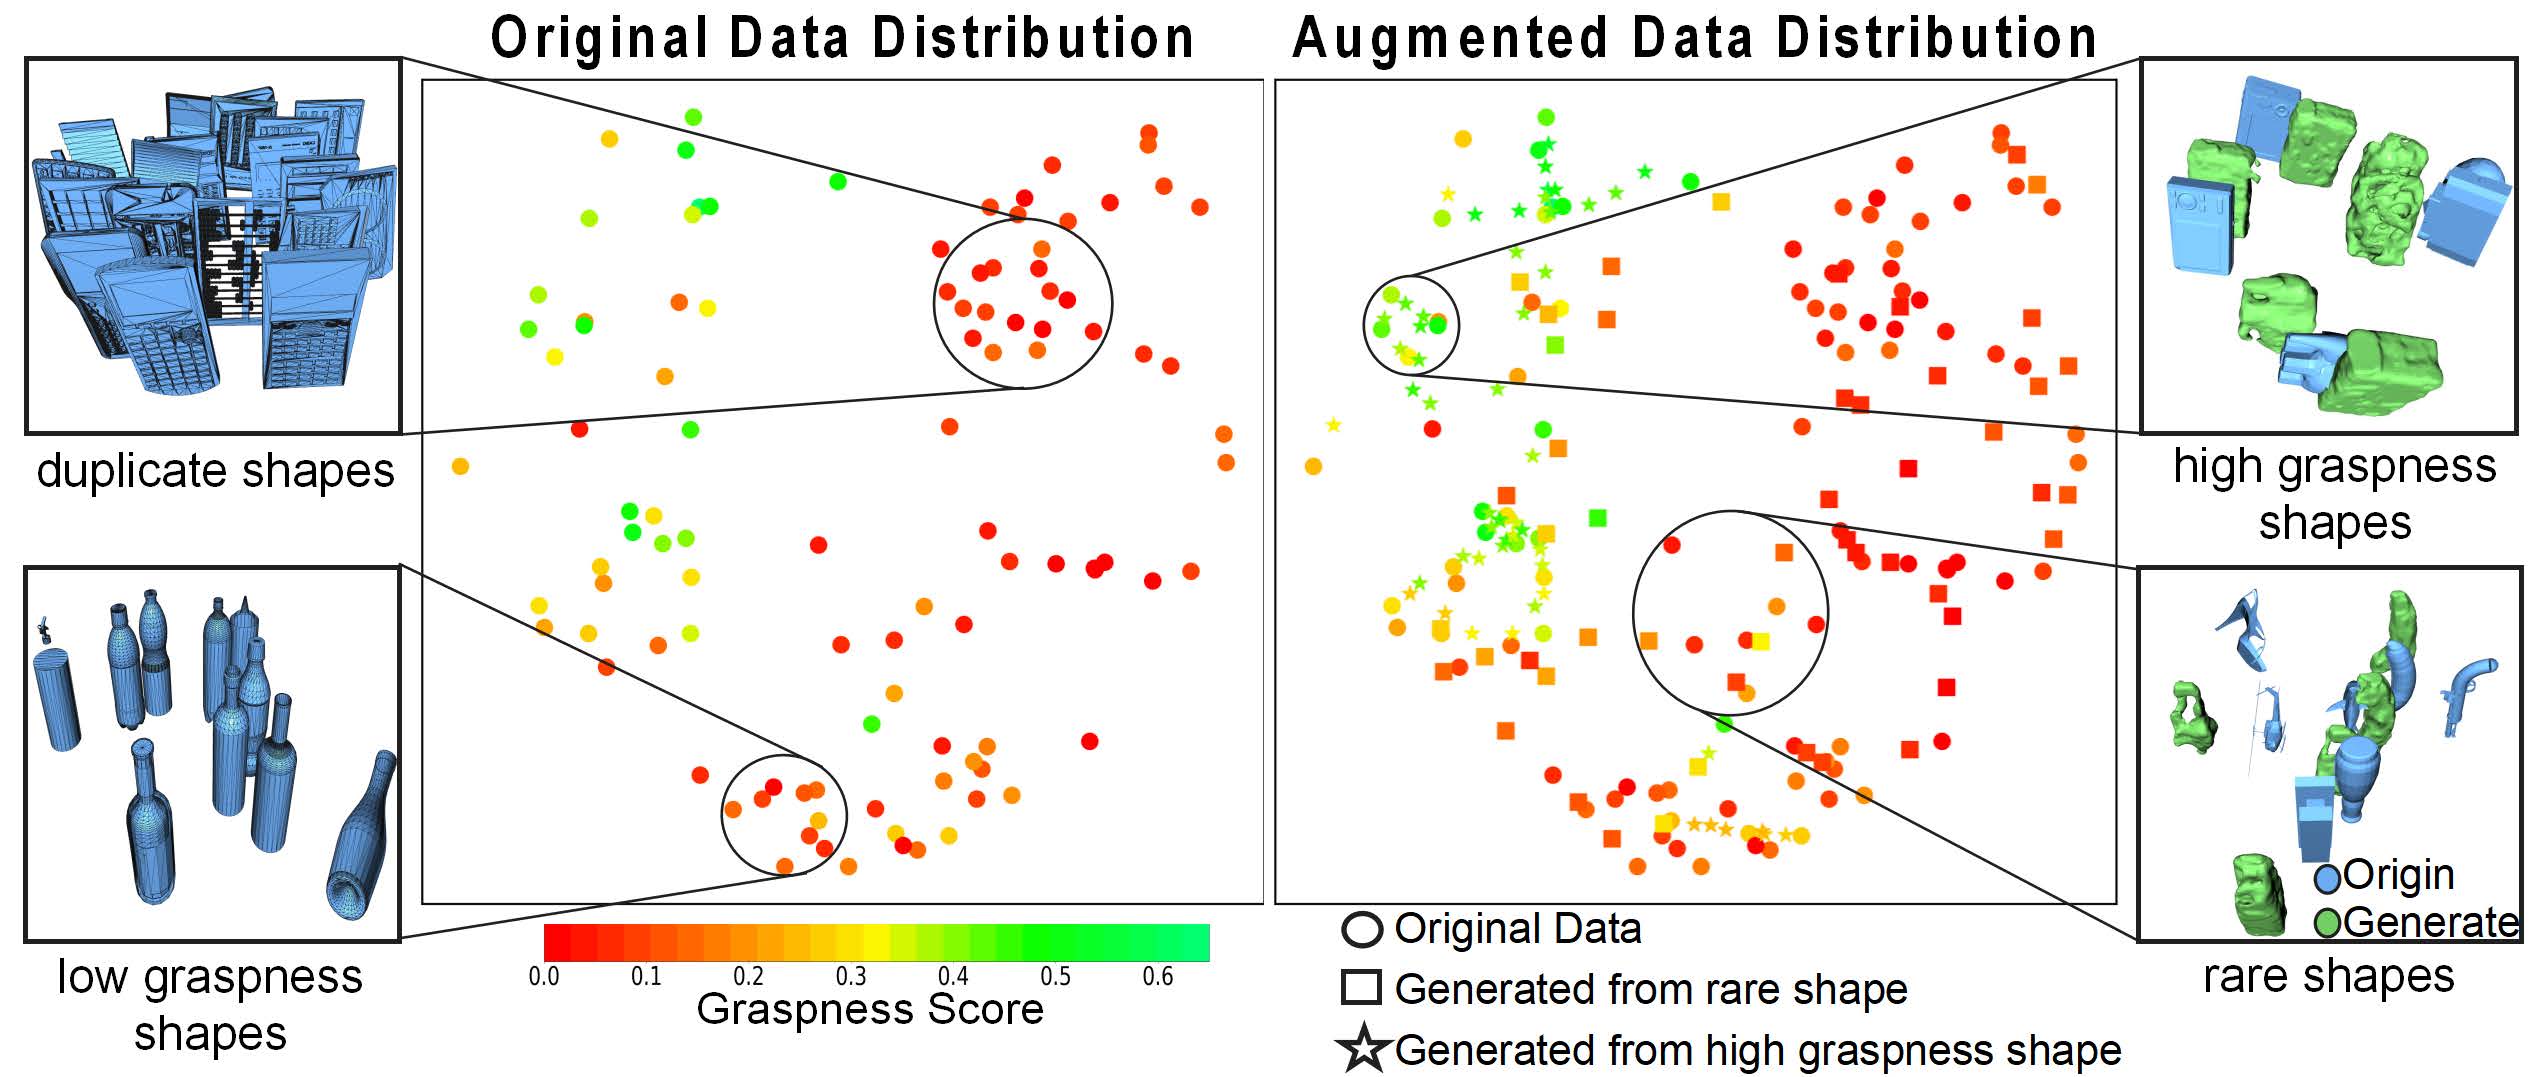
- Y. He, W. Pan, R. Zhang, and M. Li. Towards Understanding Of Human Cervical Spine With EMG Signal. ROBIO 2024, 1989–1995.

- P. Guo, C.-G. Yang, X. Li, Y. Zhang, and M. Li. A Review on Robotized Automated Lay-up Technology for Composite Material Manufacturing. Acta Automatica Sinica, 50(5), 873–897.

- J. Lin, J. Ke, R. Xiao, X. Jiang, M. Li, X. Xiao, and Z. Guo. Bioinspired Bidirectional Stiffening Soft Actuators Enable Versatile and Robust Grasping. Soft Robotics, 11(3), 494–507.

2023
- Y. Zhuang, B. Wang, J. Huai, and M. Li. 4D iRIOM: 4D Imaging Radar Inertial Odometry and Mapping. IEEE Robotics and Automation Letters, 8(6), 3246–3253.

- J. Pan, Z. Fu, H. Yue, X. Lei, M. Li, and X. Chen. Toward Simultaneous Coordinate Calibrations of AX=YB Problem by the LMI-SDP Optimization. IEEE Transactions on Automation Science and Engineering, 20(4), 2445–2453.

- D. Huang, C. Yang, M. Li, H. Huang, and Y. Li. Motion Regulation Solutions to Holding and Moving an Object for Single-Leader-Dual-Follower Teleoperation. IEEE Transactions on Industrial Informatics, 19(10), 10170–10181.

- F. Zhao, B. Huang, M. Li, M. Li, Z. Fu, Z. Lei, and M. Li. A Novel Tactile Palm for Robotic Object Manipulation. ICIRA 2023, 81–92.

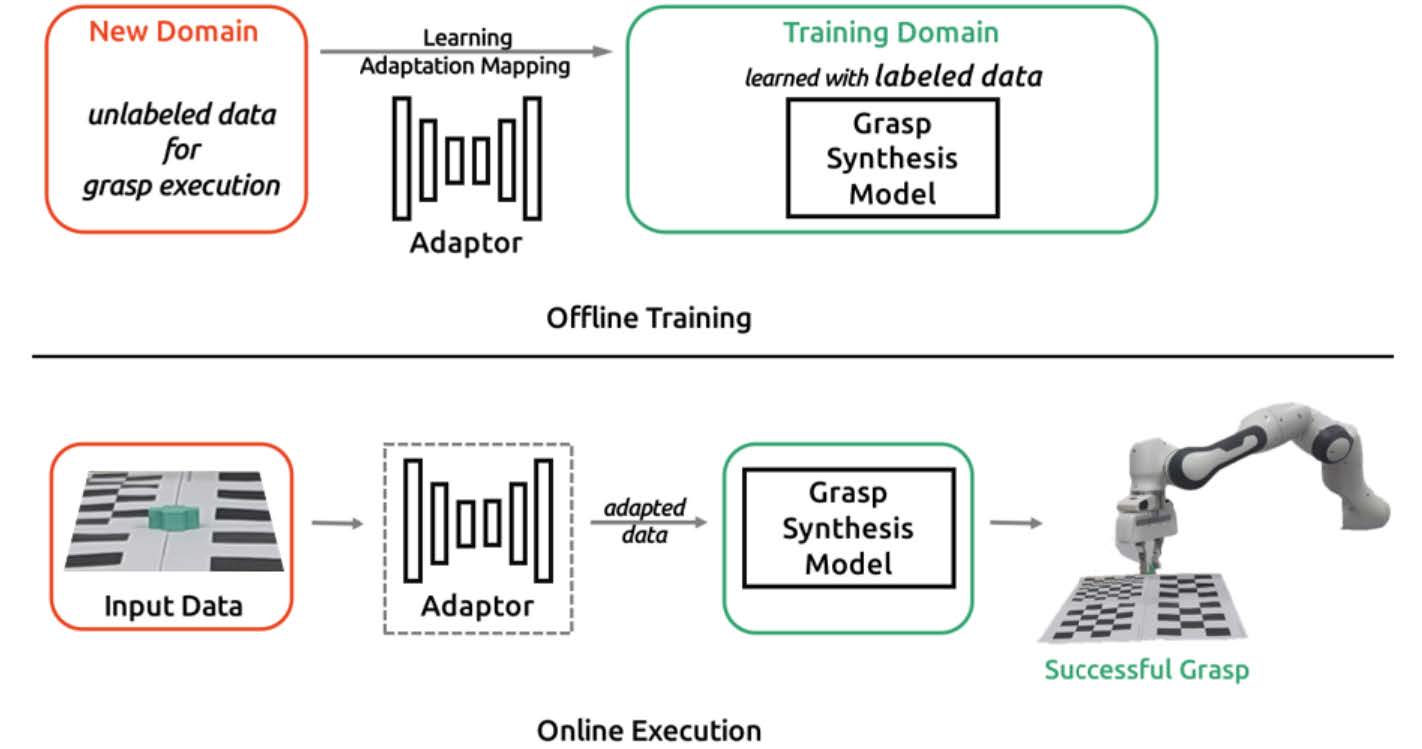
- Y. Chen, J. Jiang, R. Lei, Y. Bekiroglu, F. Chen, and M. Li. GraspAda: Deep Grasp Adaptation through Domain Transfer. ICRA 2023, 10268–10274.
- Y. Tu, J. Jiang, S. Li, N. Hendrich, M. Li, and J. Zhang. PoseFusion: Robust Object-in-Hand Pose Estimation with SelectLSTM. IROS 2023, 6839–6846.

2022
- Z. Lei, X. Deng, Y. Wang, Z. Li, X. Xiao, D. Han, F. Chen, and M. Li. A Biomimetic Tactile Palm for Robotic Object Manipulation. IEEE Robotics and Automation Letters.

- M. Li et al. Robot Learning to Search Objects in Cluttered Environments Using Maximum Information-based Method. IEEE CYBER 2022 — Best Paper Award Finalist.

- Y. Wang, Y. Tu, Y. He, X. Deng, Z. Lei, J. Zhang, and M. Li. Learning Friction Model for Magnet-Actuated Tethered Capsule Robot. ICRA 2022, 1323–1328.

2021
- X. Deng, Z. Lei, Y. Wang, W. Cheng, C. Yang, and M. Li. Learning Ultrasound Scanning Skills from Human Demonstrations. Science China Information Sciences.

- Y. Zhang, M. Li, and C. Yang. Robot learning system based on Dynamic Movement Primitives and Neural Network. Neurocomputing.

- X. Gao, J. Silvério, E. Pignat, S. Calinon, M. Li, and X. Xiao. Motion Mappings for Continuous Bilateral Teleoperation. IEEE Robotics and Automation Letters.

- Z. Deng and M. Li. Learning Optimal Fin-ray Finger Design for Soft Grasping. Frontiers in Robotics and AI.

- X. Deng, Y. Chen, F. Chen, and M. Li. Learning Robotic Ultrasound Scanning Skills via Human Demonstrations and Guided Explorations. ROBIO 2021, 372–378 — T.J. Tarn Best Paper Award Finalist.

- Y. Wang, Y. He, X. Deng, Z. Lei, Y. Chen, and M. Li. Learning Friction Model for Tethered Capsule Robot. ICRAE 2021.

- Y. Chen, C. Yang, M. Li, and S. Dai. Learning to Predict Action Based on B-ultrasound Image Information. ICARM 2021.

- Y. Chen, C. Yang, and M. Li. Sim-to-Real: Unknown Object Segmentation by Domain Adaptation in a Bin-picking Scenario. ICoIAS 2021.

- J. Xiong, Z. Fu, M. Li, Z. Gao, X. Zhang, and X. Chen. Trajectory-Smooth Optimization and Simulation of Dual-Robot Collaborative Welding. ICIRA 2021.

2020
- Z. Lu, M. Li, A. S. K. Annamalai, and C. Yang. Recent advances in robot-assisted echography: combining perception, control and cognition. Cognitive Computation and Systems, 2(3), 85–92.
%22%20fill%3D%22none%22%20stroke%3D%22%2356a472%22%20stroke-width%3D%223%22%20stroke-linecap%3D%22round%22%3E%0A%20%20%20%20%3Ccircle%20cx%3D%2222%22%20cy%3D%2222%22%20r%3D%2218%22%2F%3E%3Cpath%20d%3D%22M6%2022h32M22%206v32%22%2F%3E%3Cpath%20d%3D%22M10%2012l24%2020M34%2012L10%2032%22%2F%3E%0A%20%20%3C%2Fg%3E%0A%3C%2Fsvg%3E)
- J. Zhang, M. Li, Y. Feng, and C. Yang. Robotic grasp detection based on image processing and random forest. Multimedia Tools and Applications, 79(3–4), 2427–2446.

- Z. Fu, J. Pan, E. Spyrakos-Papastavridis, X. Chen, and M. Li. A Dual Quaternion-Based Approach for Coordinate Calibration of Dual Robots in Collaborative Motion. IEEE Robotics and Automation Letters, 5(3), 4086–4093.

- J. Zhang, M. Li, and C. Yang. Robotic grasp detection using effective graspable feature selection and precise classification. IJCNN 2020, 1–6.
